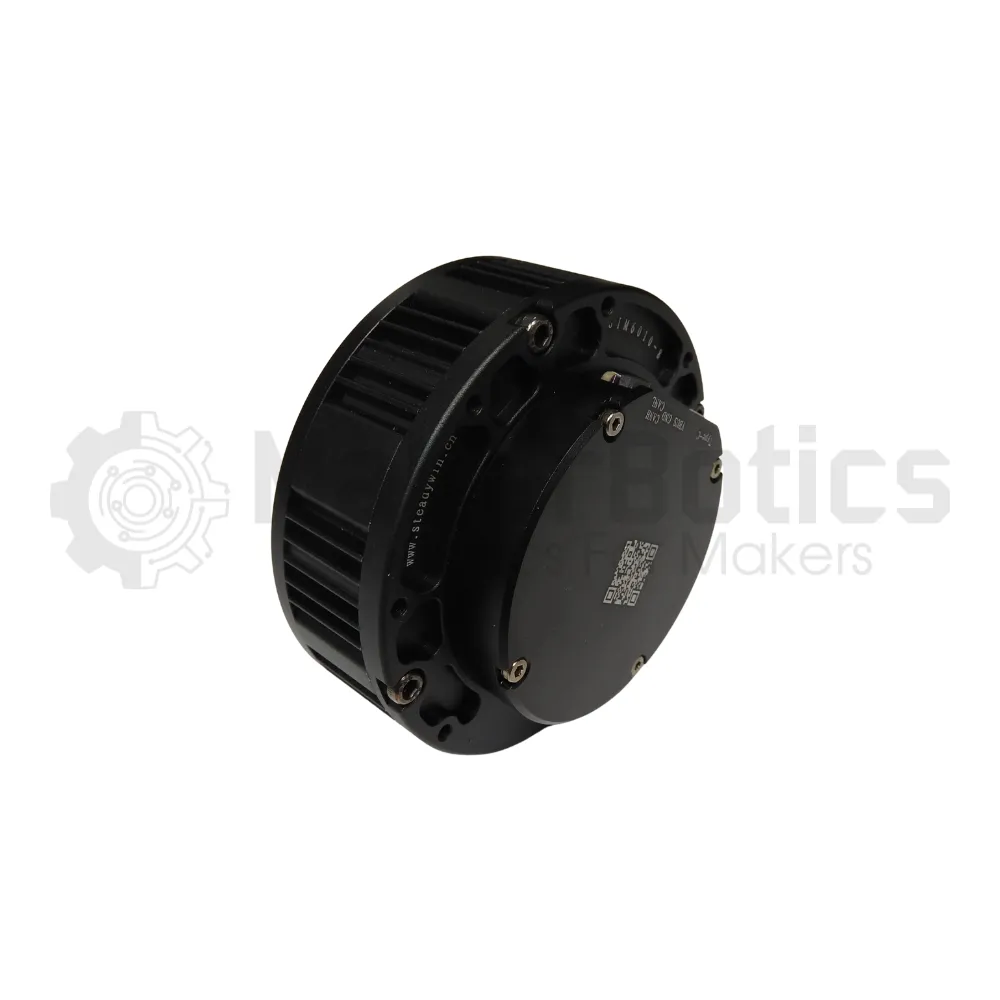
Description
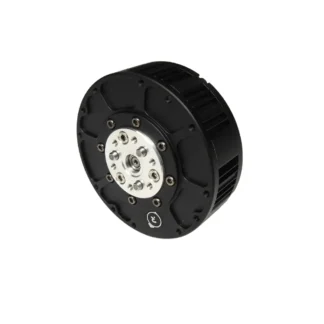
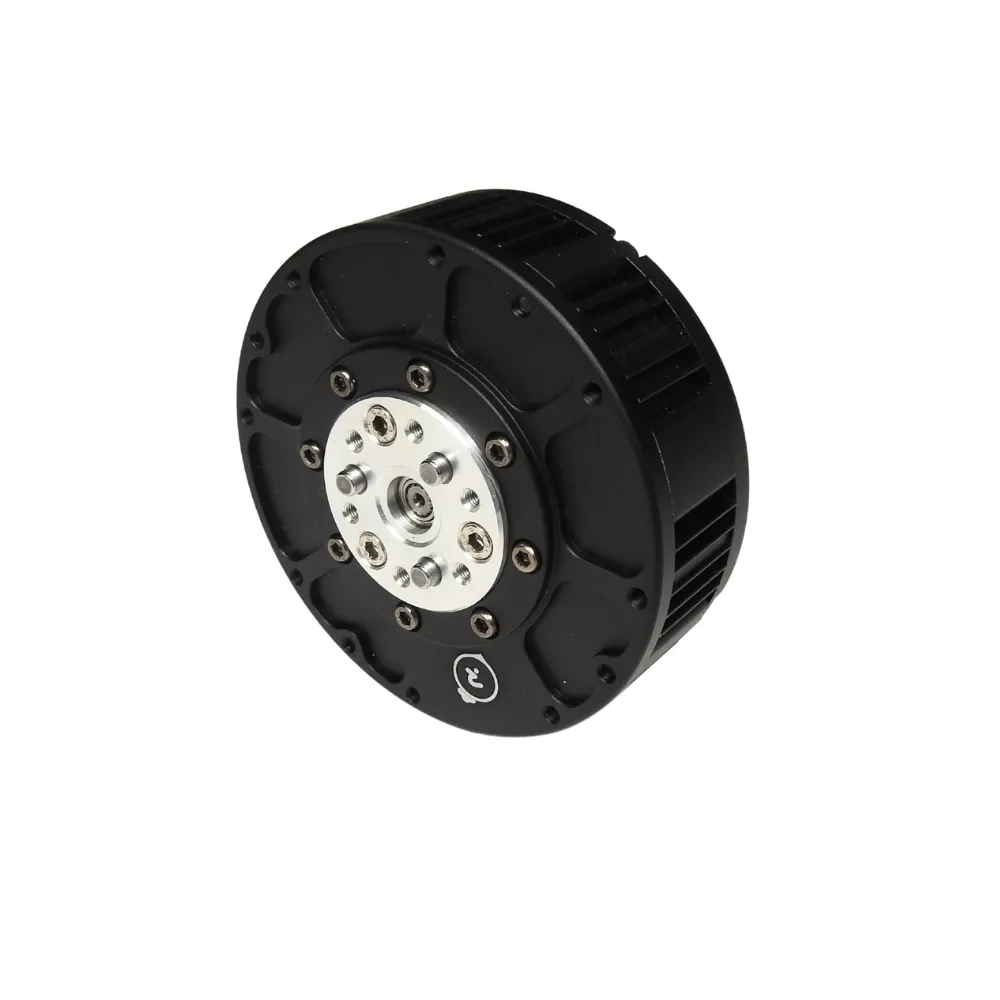
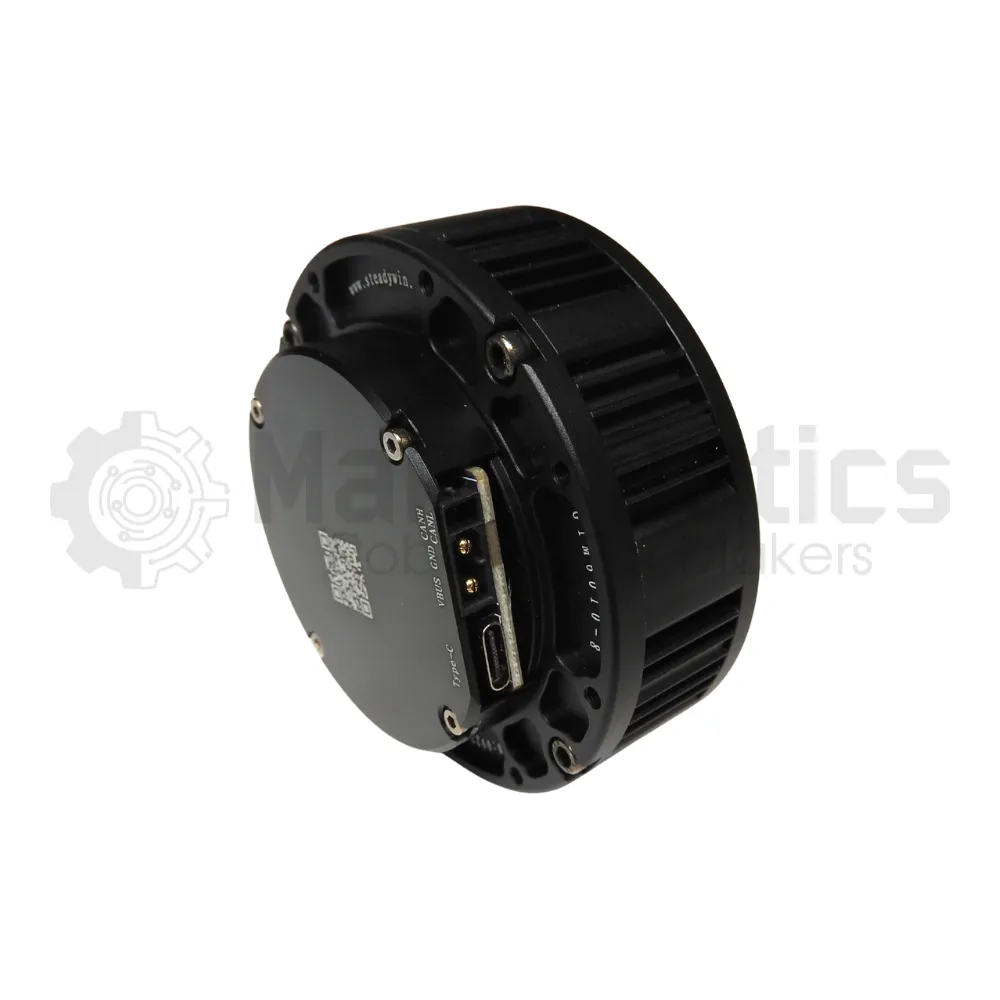
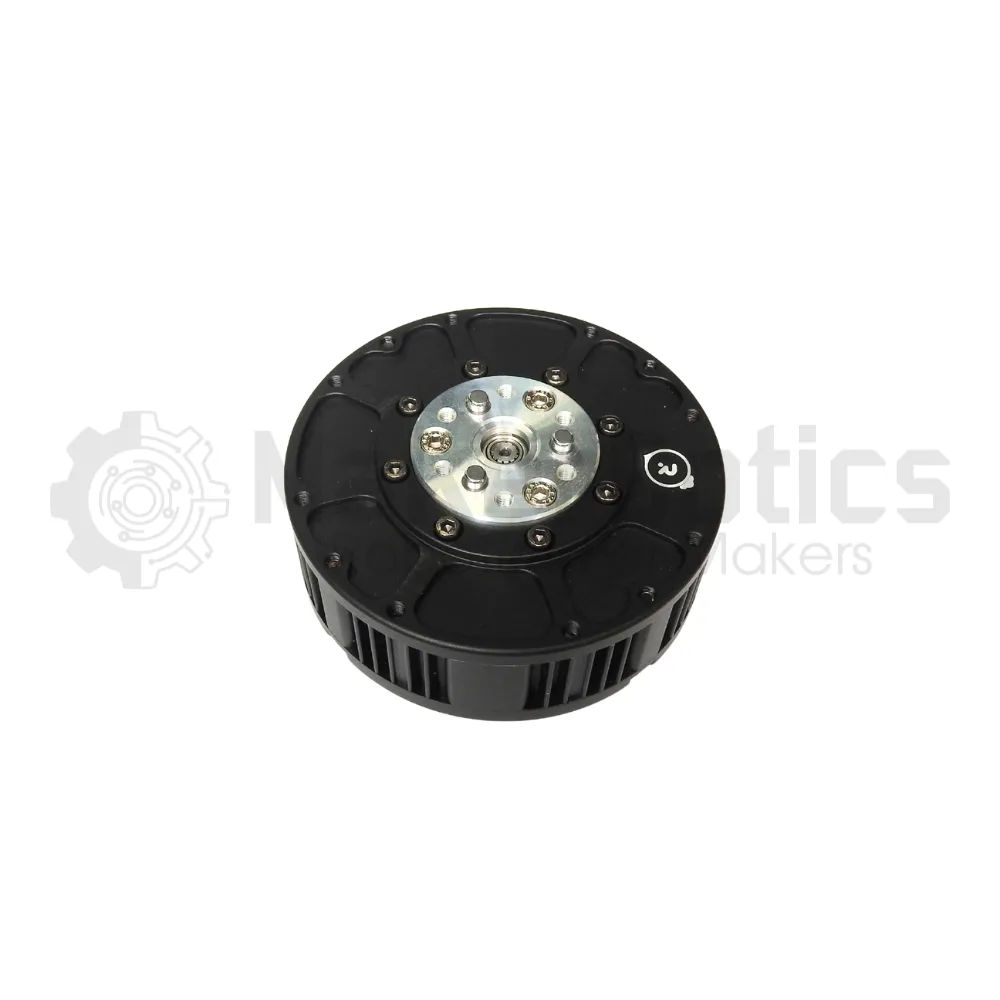
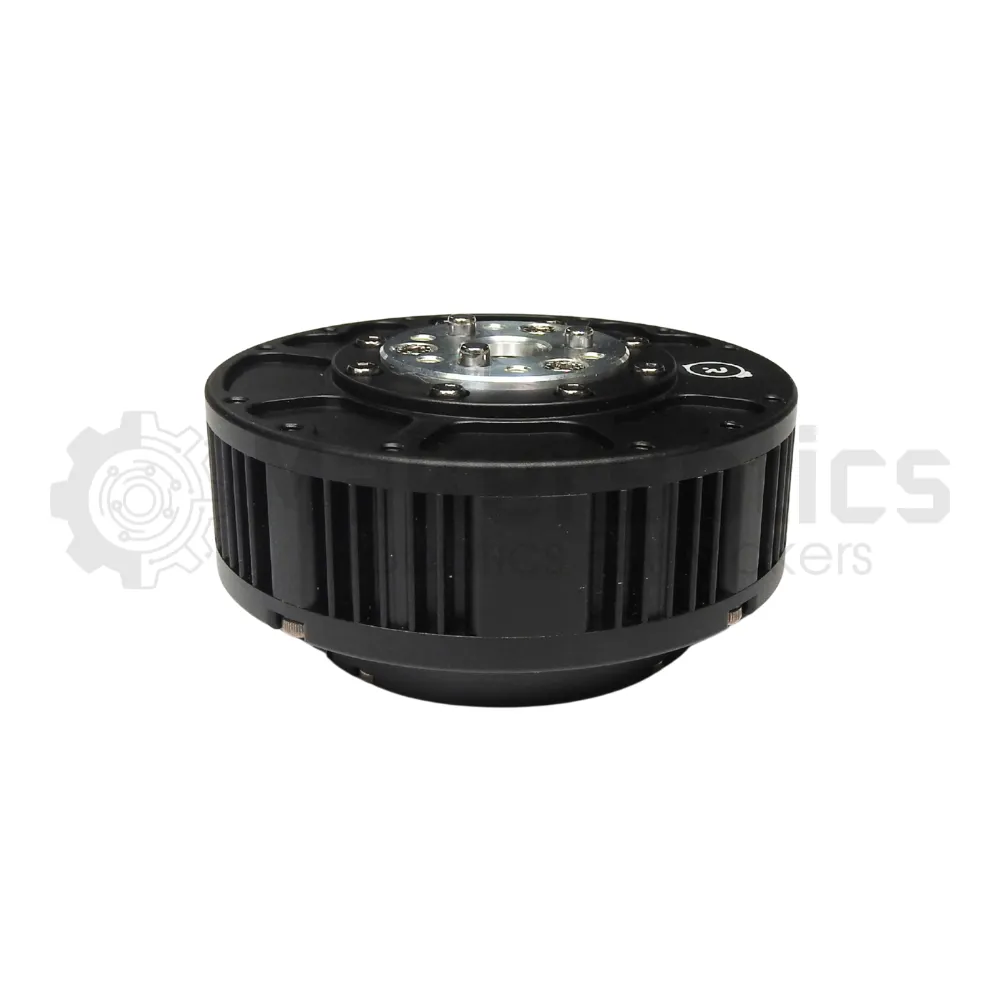
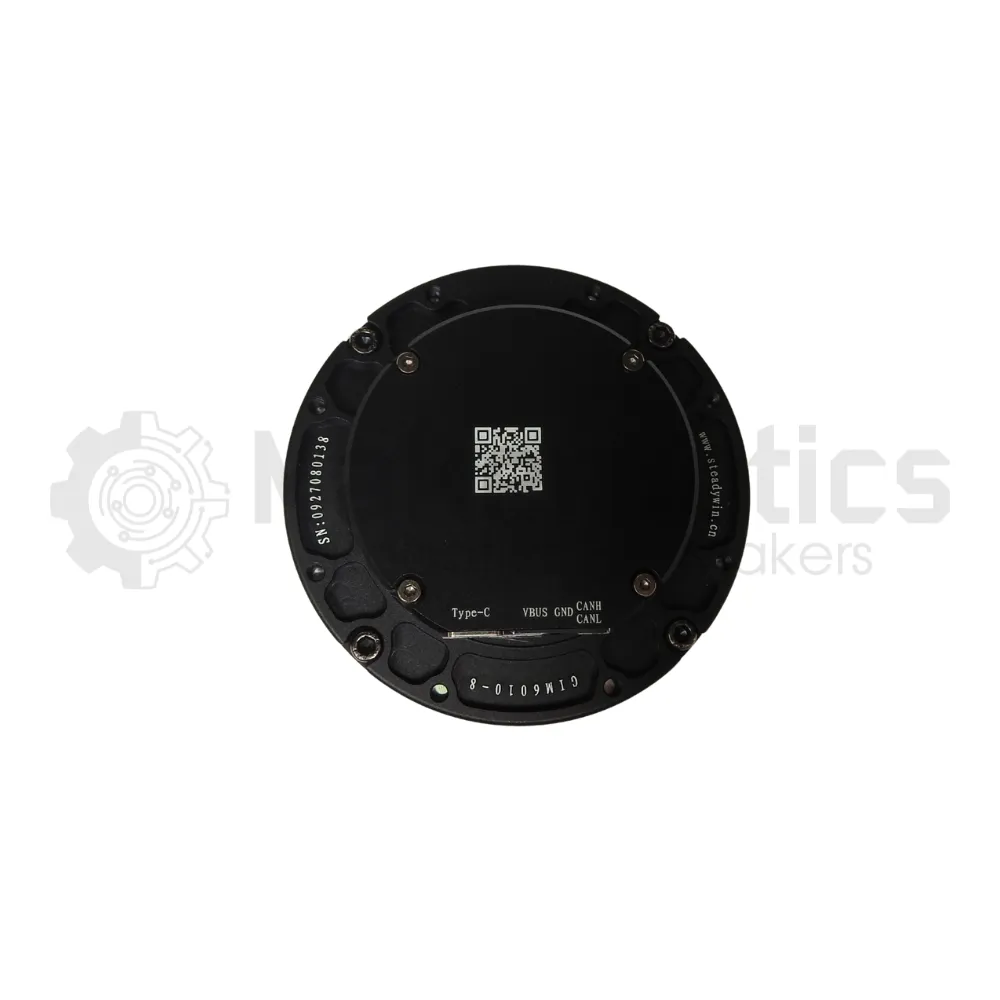
Upgrade your robotics projects with the GIM6010-8 Joint Robot Motor, engineered specifically for robotic joints and automation. This compact motor delivers up to 5N·m of rated torque and 11N·m stall torque through a rugged 8:1 steel planetary gearbox. It features versatile CAN and Type-C (USB) connectivity for flexible control options. A high-resolution 16-bit encoder ensures precise position feedback, while IP54-rated protection provides reliable performance in demanding environments.
The GIM6010-8 features a robust 8:1 steel planetary gear system that provides compact, high-torque output with minimal backlash, ensuring smooth and precise joint movement. It includes a built-in 16-bit encoder for accurate position feedback and offers a fast 7ms response time for dynamic control. Additionally, its intelligent telemetry system continuously monitors key parameters like temperature and current draw, enhancing reliability and protecting the motor during operation.
GIM6010-8 Specifications
| Description | Value |
| Nominal Voltage | 24VDC |
| Voltage Range | 16-28VDC |
| Rated Power | 65W |
| Rated Torque | 5NM |
| Stall Torque | 11NM |
| Rated Current | 10A DC |
| Stall Current | 25A DC |
| Speed Constant | 12.3 |
| Torque Constant | 0.47 |
| Pole Pairs | 14 |
| Gear Reduction | 8:01 |
| Gear Type | Planetary |
| Backlash | 5~10 Arc Minutes |
| Max Axial Load | 600N |
| Max Radial Load | 800N |
| Encoder Resolution | 12 Bit |
| Ingress Protection Rating | IP54 |
| Operating Temperature Range | -20°C to +80°C |
| Communication Protocol | CANBUS/RS485 |
Ideal for precision motion in space-constrained applications, the GIM6010-8 offers robust performance and flexible integration for next-generation robotics.
Communication Protocol:
The GIM6010-8 supports CAN bus and Type-C (USB) communication, enabling both real-time motor control and easy configuration through a direct USB connection—ideal for rapid development and debugging. CAN bus ensures robust, high-speed communication in multi-device networks, while the USB interface simplifies setup and tuning without the need for additional adapters or interfaces.
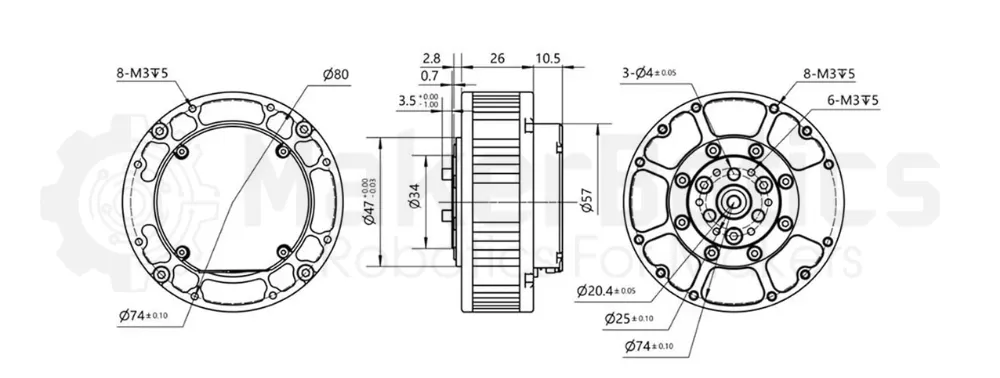
Technical Drawings
All Dimensions in mm
Resources: